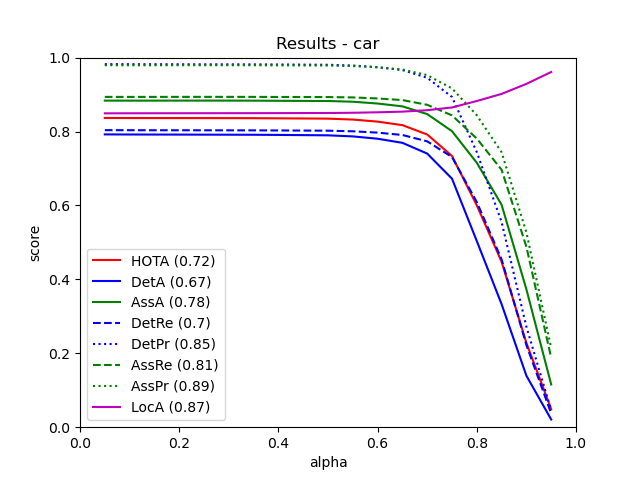
From all 29 test sequences, our benchmark computes the HOTA tracking metrics (HOTA, DetA, AssA, DetRe, DetPr, AssRe, AssPr, LocA) [1] as well as the CLEARMOT, MT/PT/ML, identity switches, and fragmentation [2,3] metrics.
The tables below show all of these metrics.
| Benchmark |
HOTA |
DetA |
AssA |
DetRe |
DetPr |
AssRe |
AssPr |
LocA |
| CAR |
72.04 % |
66.62 % |
78.48 % |
69.72 % |
85.21 % |
81.43 % |
88.99 % |
86.58 % |
| Benchmark |
TP |
FP |
FN |
| CAR |
27592 |
6800 |
546 |
| Benchmark |
MOTA |
MOTP |
MODA |
IDSW |
sMOTA |
| CAR |
78.32 % |
85.00 % |
78.64 % |
109 |
66.29 % |
| Benchmark |
MT rate |
PT rate |
ML rate |
FRAG |
| CAR |
64.00 % |
12.15 % |
23.85 % |
417 |
| Benchmark |
# Dets |
# Tracks |
| CAR |
28138 |
542 |
This table as LaTeX
|
[1] J. Luiten, A. Os̆ep, P. Dendorfer, P. Torr, A. Geiger, L. Leal-Taixé, B. Leibe:
HOTA: A Higher Order Metric for Evaluating Multi-object Tracking. IJCV 2020.
[2] K. Bernardin, R. Stiefelhagen:
Evaluating Multiple Object Tracking Performance: The CLEAR MOT Metrics. JIVP 2008.
[3] Y. Li, C. Huang, R. Nevatia:
Learning to associate: HybridBoosted multi-target tracker for crowded scene. CVPR 2009.