Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Method

Voxel Interaction and Quality Calibration Network [VIQC-Net]
[Anonymous Submission]

Submitted on 23 Oct. 2026 05:47 by
[Anonymous Submission]

Running time:0.13 s
Environment:GPU @ 2.5 Ghz (Python)

Method Description:
VIQC-Net is a LiDAR-only two-stage 3D object
detector built on a sparse VoxelNeXt backbone.
FICR aggregates local cross-scale voxel
information to enhance sparse bird's-eye-view
features. SmallLQA estimates localization quality
for class-specific confidence fusion. Multi-scale
voxel RoI pooling refines proposals, followed by
class-wise size calibration using training-set
statistics. The submitted single model was trained
from scratch for 80 epochs on all 7,481 labeled
KITTI training frames, without external training
data or RGB image features.
Parameters:
Class order: Car, Pedestrian, Cyclist.
Fixed size calibration alpha: [0.10, 0.50, 0.75].
Fixed quality fusion beta: [0.75, 0.75, 0.75].
RoI pooling grid: 6 x 6 x 6.
Training RoIs per frame: 160.
Pre-refinement NMS threshold: 0.7.
Final NMS threshold: 0.1.
Class size priors are computed from all 7,481
labeled training frames.

Runtime: 0.1259 seconds per frame on one NVIDIA
L40, measured over the original test loop,
including data loading and prediction export.
Subsequent offline angle normalization and
geometric visibility correction are excluded from
this timing.
Latex Bibtex:

Detailed Results

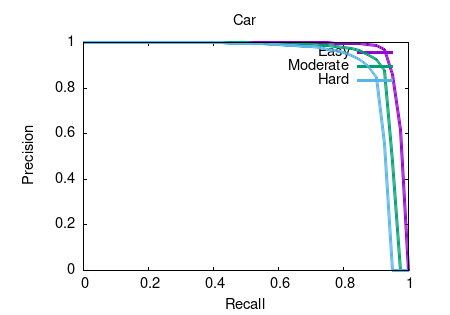
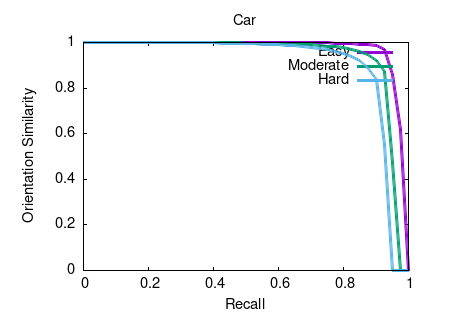
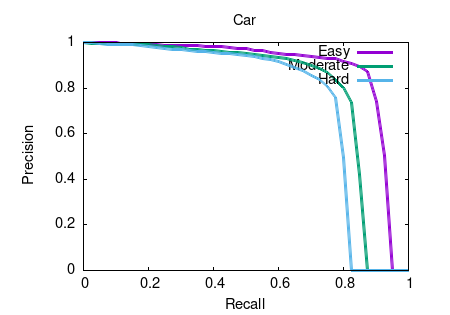
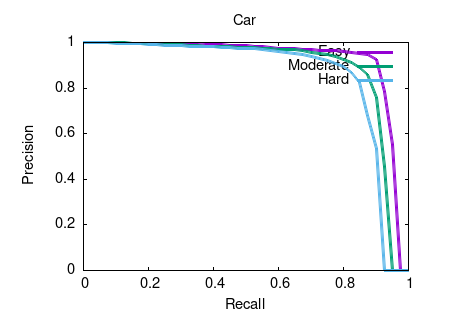
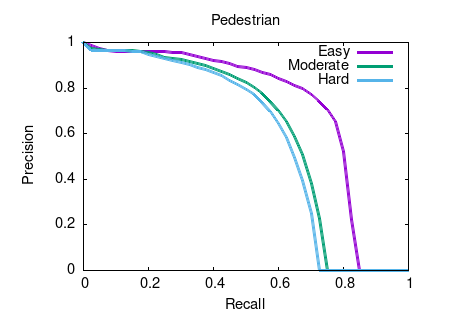
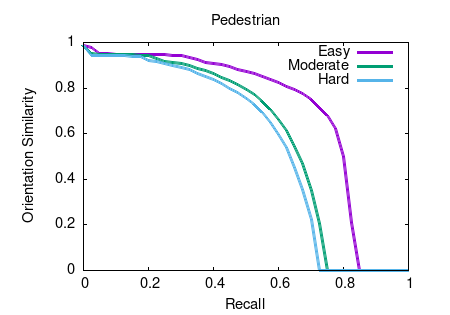
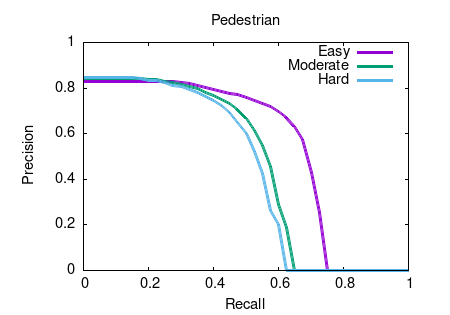
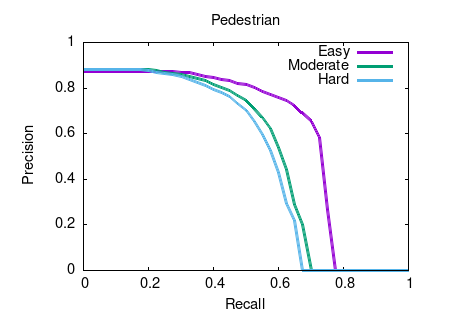
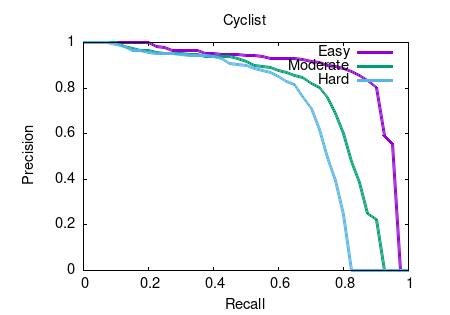
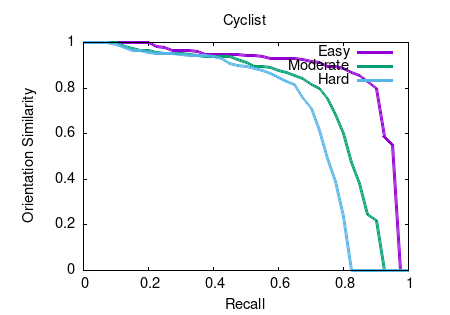
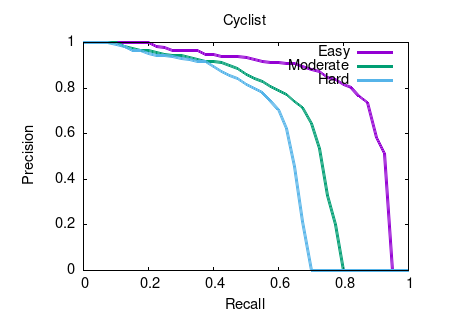
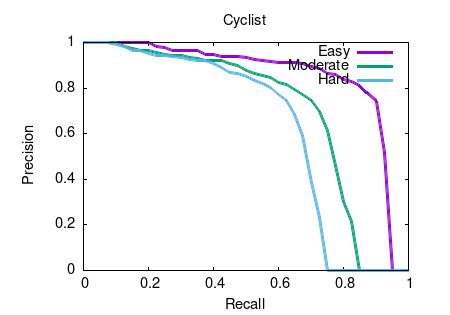
Object detection and orientation estimation results. Results for object detection are given in terms of average precision (AP) and results for joint object detection and orientation estimation are provided in terms of average orientation similarity (AOS).


Benchmark Easy Moderate Hard
Car (Detection) 96.01 % 92.62 % 89.81 %
Car (Orientation) 96.00 % 92.55 % 89.68 %
Car (3D Detection) 87.52 % 78.91 % 73.96 %
Car (Bird's Eye View) 91.70 % 88.01 % 84.96 %
Pedestrian (Detection) 71.03 % 59.59 % 57.00 %
Pedestrian (Orientation) 69.64 % 57.78 % 54.90 %
Pedestrian (3D Detection) 54.26 % 45.38 % 42.98 %
Pedestrian (Bird's Eye View) 59.98 % 51.15 % 48.68 %
Cyclist (Detection) 87.65 % 75.83 % 68.57 %
Cyclist (Orientation) 87.53 % 75.66 % 68.40 %
Cyclist (3D Detection) 83.76 % 65.37 % 57.46 %
Cyclist (Bird's Eye View) 84.75 % 69.47 % 61.59 %
This table as LaTeX


2D object detection results.
This figure as: png eps pdf txt gnuplot


Orientation estimation results.
This figure as: png eps pdf txt gnuplot


3D object detection results.
This figure as: png eps pdf txt gnuplot


Bird's eye view results.
This figure as: png eps pdf txt gnuplot


2D object detection results.
This figure as: png eps pdf txt gnuplot


Orientation estimation results.
This figure as: png eps pdf txt gnuplot


3D object detection results.
This figure as: png eps pdf txt gnuplot


Bird's eye view results.
This figure as: png eps pdf txt gnuplot


2D object detection results.
This figure as: png eps pdf txt gnuplot


Orientation estimation results.
This figure as: png eps pdf txt gnuplot


3D object detection results.
This figure as: png eps pdf txt gnuplot


Bird's eye view results.
This figure as: png eps pdf txt gnuplot


eXTReMe Tracker