Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Method

Monocular Localization-Guided Depth Correction [MonoLDC]


Submitted on 6 Nov. 2026 18:03 by
玮杰 王 (西南交通大学)

Running time:0.02 s
Environment:GPU @ 2.5 Ghz (Python)

Method Description:
MonoLDC detects 3D objects from a single
calibrated RGB image. It augments the detector's
feature pyramid with depth-aware visual features.
In later decoder layers, the preceding layer's box
predictions guide object-specific sampling from a
shared multiscale depth memory. The current box
geometry and boundary uncertainty condition a
learned residual that refines a projection-based
depth estimate.
Parameters:
SSLD-pretrained ResNet-50, input size = 1280 x 384,
top-k = 50, classification threshold = 0.20.
Runtime measured at batch size 8 on one RTX 4090.
Latex Bibtex:

Detailed Results

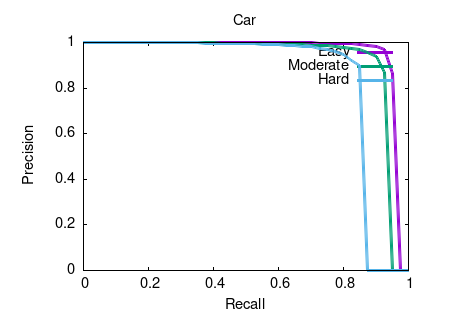
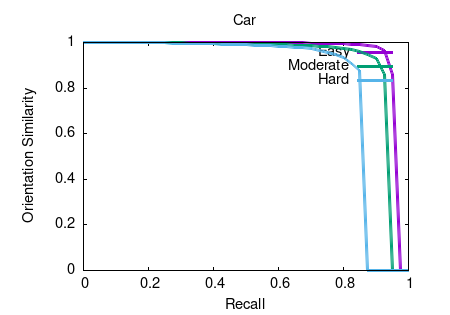
Object detection and orientation estimation results. Results for object detection are given in terms of average precision (AP) and results for joint object detection and orientation estimation are provided in terms of average orientation similarity (AOS).


Benchmark Easy Moderate Hard
Car (Detection) 94.42 % 91.41 % 83.88 %
Car (Orientation) 94.34 % 91.13 % 83.43 %
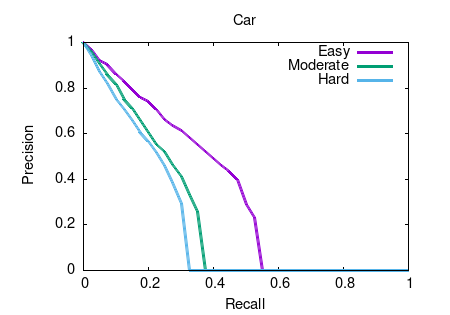
Car (3D Detection) 33.39 % 22.03 % 18.94 %
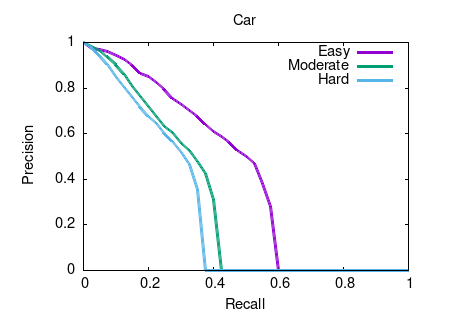
Car (Bird's Eye View) 41.04 % 27.85 % 24.43 %
This table as LaTeX


2D object detection results.
This figure as: png eps pdf txt gnuplot


Orientation estimation results.
This figure as: png eps pdf txt gnuplot


3D object detection results.
This figure as: png eps pdf txt gnuplot


Bird's eye view results.
This figure as: png eps pdf txt gnuplot


eXTReMe Tracker